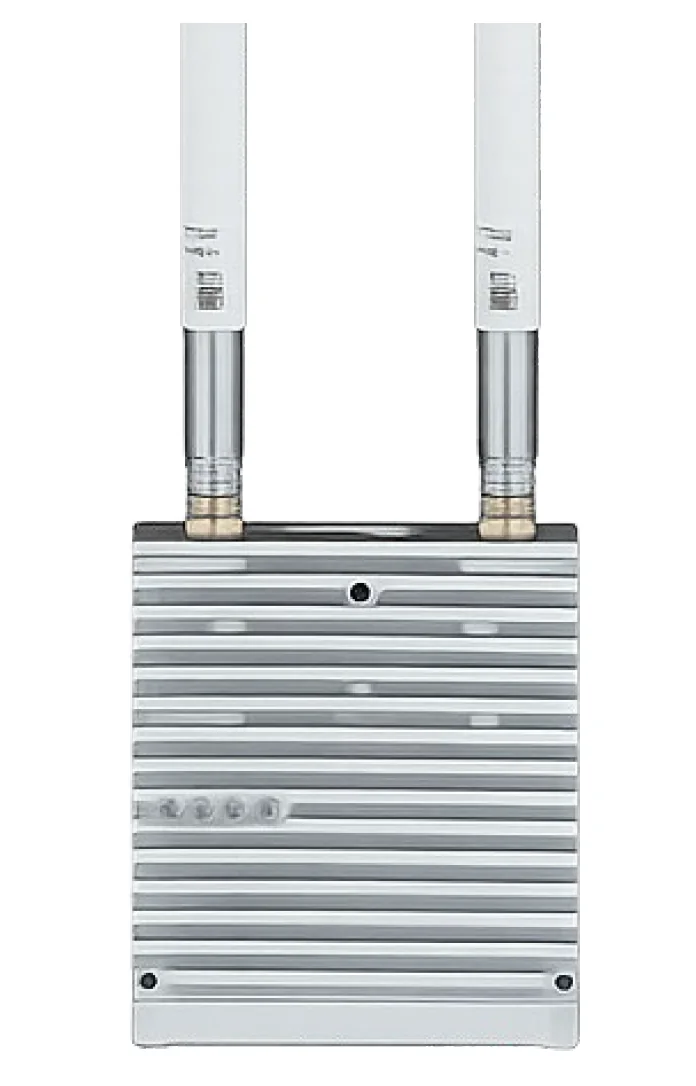
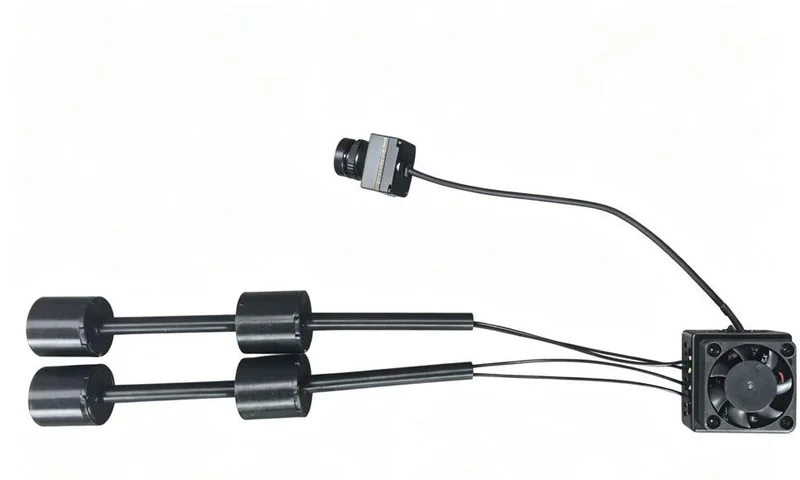
 C405 MAX
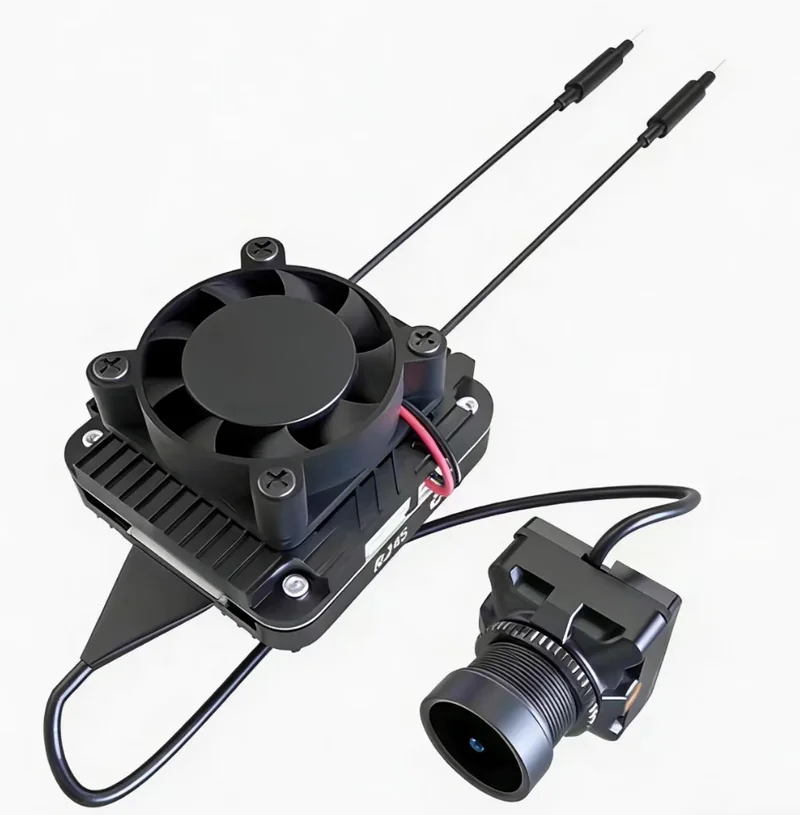 ZYRO Air
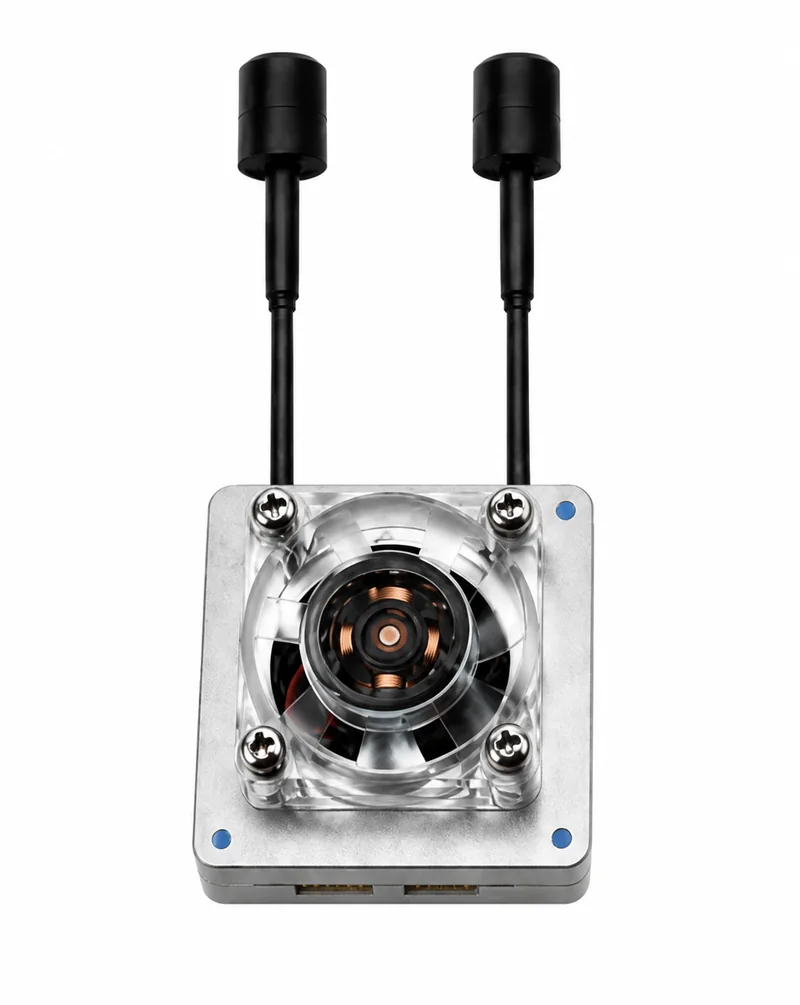 ZYRO Link
 ZYRO Thermal
ZYRO MeshFlow / Air & Ground
Air. Ground. Connected.
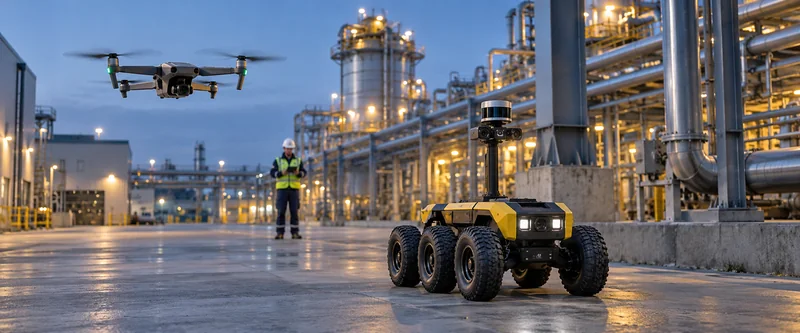
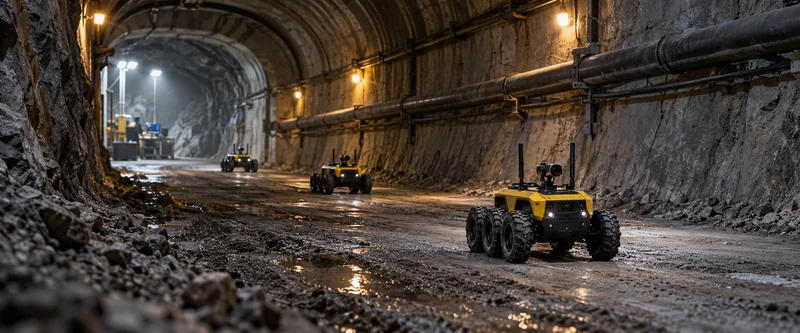
Connect inspection from above and at ground level. The MeshFlow air–ground concept brings inspection drones, a mobile robot and a control station onto a shared wireless mesh for video, telemetry and control data. When industrial structures block a direct connection, nearby nodes can relay information over a reachable path. If that route is lost, an available alternative can reconnect the robot to the control station. Aerial and ground views give operators a shared picture of the site, with people directing the inspection. Network behaviour and performance depend on node placement, configuration and radio conditions.
Discuss this solution ↗Read the video transcript
In complex industrial environments, every operation starts with a strong network connection.
From the air to the ground, inspection drones and mobile robots become one connected working team.
Four nodes share a mesh, carrying video, telemetry, and control data across the site.
When structures block direct links, nearby nodes relay information around obstacles through an available path.
If one route is lost, the network can adapt, using an available alternative to restore communication.
Adaptive frequency hopping helps the system respond to changing conditions across the radio environment.
Inspect from above. Explore at ground level. Bring different perspectives together, with people in control.
ZYRO MeshFlow. Connecting air and ground. Moving operations forward.
Text from the supplied English script. The industrial scenes, routes and radio-channel graphics illustrate concepts; they are not live feeds, measured spectrum or validated performance results.
Air and ground perspectives
Bring aerial inspection and a ground-level robot view into the same operational concept.
Video, telemetry and control
Connect the different platform roles through a shared wireless IP network.
Available relay paths
Illustrate paths around obstructions and an alternate route when a reachable connection is available.
The concept in the film
One connected
air–ground team.
The film gives four nodes distinct roles: control station C, inspection drone A, relay drone B and ground robot R. The diagrams show concept routes, with people in control.
- C
Control station
Human operators receive the shared perspectives and direct the inspection.
- A
Inspection drone
An aerial viewpoint and the primary illustrated relay path.
- B
Relay drone
An alternative relay role when a reachable backup connection is available.
- R
Ground robot
A ground-level inspection perspective in the air–ground concept.
Relay around an obstruction
The film shows the robot reaching the control station through inspection drone A when an industrial structure blocks the direct link.
Use an available alternative
When the robot-to-drone-A link becomes unavailable, the illustrated network uses relay drone B if that alternate path is reachable.
Explore the building blocks
Start with your platform.
Compare the related products with your platform and interface requirements.